Description
 1. Unboxing & Physical Snapshot
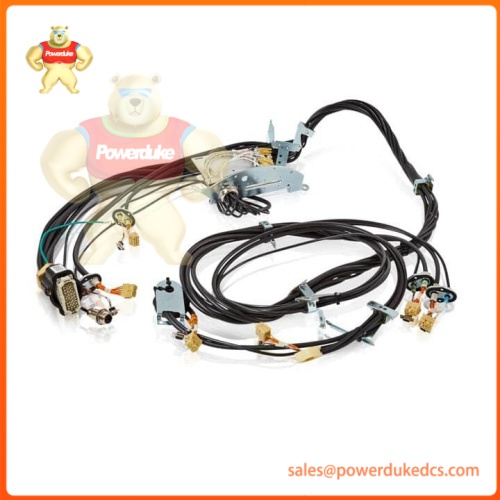
- Model & Brand: ABB Robotics — 1-6 Axis Internal Manipulator Cable Harness, Part Number 3HAC025054-001.
- Physical Dimensions: Custom multi-core routed industrial cable assembly bundle (tailored to specific ABB robot arm length profiles, typically 3 to 5 meters in routed length).
- Estimated Shipping Weight: 3.80 kg (Including heavy-duty coiled protective sleeving, moisture barrier bag, and reinforced logistics carton).
- What’s in the Box: Complete 1-6 axis internal harness assembly featuring pre-terminated heavy-duty industrial connectors, copper shielding mesh, strain-relief boots, and factory conformity documentation.
2. Product Introduction
Designed to endure continuous multi-axis articulation, this internal harness routes power, resolver feedback, and brake control signals through the heart of the robotic manipulator arm.
Routed directly through the internal hollow wrist and casting channels of high-performance ABB industrial robots, the assembly flexes millions of times under high-acceleration torsion profiles. (Robot maintenance engineers depend on this specific OEM cable tier to prevent intermittent signal drops, resolver faults, and unexpected emergency stop trips during high-speed production cycles.)
3. Core Technical Specifications
| Parameter | Value |
| Component Type | Internal Manipulator 1-6 Axis Cable Harness |
| Conductor Design | High-flex stranded copper conductors with oil-resistant PUR outer jacket |
| Shielding Architecture | Individual and overall braided tinned-copper electromagnetic shielding |
| Mechanical Endurance | Designed for millions of continuous bending and torsional articulation cycles |
| Operating Temperature | -10°C to +55°C (+14°F to +131°F) internal arm environment |
| Connector Configuration | Factory-molded heavy-duty industrial circular connectors |
| Chemical Resistance | Resistant to standard automotive coolants, hydraulic oils, and synthetic greases |
| Compatibility | Specific ABB multi-axis robot arm models |
4. Global Compliance & Industry Certifications
Safety auditors and robotic cell integrators enforcing ISO 10218 safety standards demand strict material and electrical compliance for internal manipulator wiring.
- Expected Certifications: CE Mark, RoHS environmental alignment, and compliance with international industrial machinery safety directives for articulated robots.
- Safety Relevance: High-integrity insulation and robust grounding shields prevent electrical cross-talk and high-voltage motor PWM noise from corrupting low-voltage resolver feedback loops, avoiding erratic robot trajectory deviations.
- Audit Directive: Verify specific lot certifications with OEM. Manufacturing date codes and revision tags must cross-reference cleanly with the robot cell’s maintenance history logs.
5. Long-Term Storage & Asset Preservation Guide
Complex robotic cable harnesses kept in warehouse inventory degrade structurally if stored under improper tension or temperature extremes.
- Coil Radius Management: Never tightly kink or sharply bend the cable bundle during storage; maintain natural, sweeping loop radiuses (at least 15x the cable outer diameter) to prevent internal conductor fatigue.
- Polymer Protection: Store harnesses inside a climate-controlled room under 60% relative humidity, away from direct sunlight or ozone-generating electrical equipment that degrades polyurethane (PUR) outer jackets.
- Connector Care: Keep protective plastic dust caps firmly seated on all pre-terminated connector ends to prevent airborne dust, metal shavings, or moisture from contaminating gold contact pins.
6. Physical Installation Prerequisites
Replacing an internal robot arm harness requires meticulous mechanical routing and strict adherence to service manual guidelines.
- Arm Disassembly Protocol: Follow the exact ABB mechanical disassembly sequence to open the robot arm cast covers, ensuring internal guide clips and protective sleeves are reinstalled correctly to prevent chafing against sharp casting edges.
- Torsion Relief: Route the harness with specified slack loops to ensure that axis rotation limits do not place tensile stress on terminal connectors during full-range articulation.
- Grounding Continuity: Verify that all internal shielding drain wires and ground bonding straps are secured firmly to the internal arm chassis studs to maintain EMC compliance.
7. Buyer’s FAQ (Logistics & Compliance Focus)
Q: What Harmonized System (HS) Tariff Code applies to global shipments of this robot cable assembly?
A: Insulated electrical wire harnesses and cables fitted with connectors for machinery typically clear under HS Code 8544.42 (Other electric conductors, for a voltage not exceeding 1000 V, fitted with connectors). Confirm exact sub-headings with your customs broker.
Q: Does importing this robotic spare part require a Certificate of Origin (COO)?
A: Yes. Securing an authentic Certificate of Origin from your procurement partner verifies manufacturing provenance, which is vital for plant quality assurance and audit compliance.
Q: Are these replacement harnesses identical to factory-installed original parts?
A: Yes. Genuine OEM parts match exact conductor gauges, shielding densities, and connector pinouts required to maintain the robot’s dynamic performance ratings and payload specifications.